Awesome FlexiTac
Research built with FlexiTac, inspired by it, and the prior work it grew out of, spanning robot learning, computer vision, physics simulation, mechanical design, legged and humanoid robotics, haptics, wearable electronics, and industry.
Papers built on FlexiTac have been published at CoRL, NeurIPS, ICRA, IROS, ECCV and npj Robotics.
- Built with FlexiTac
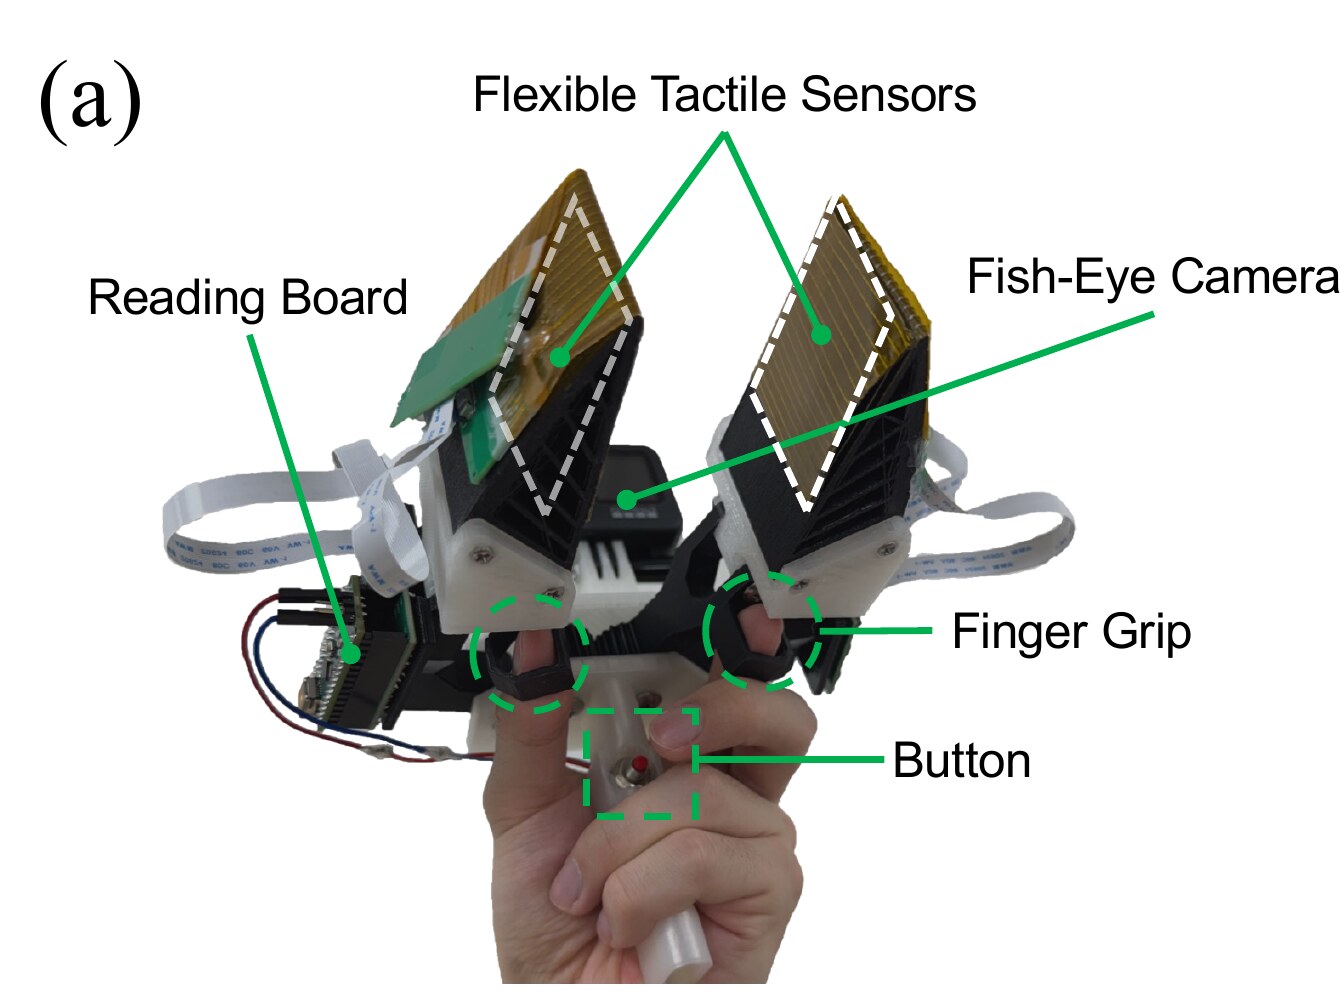
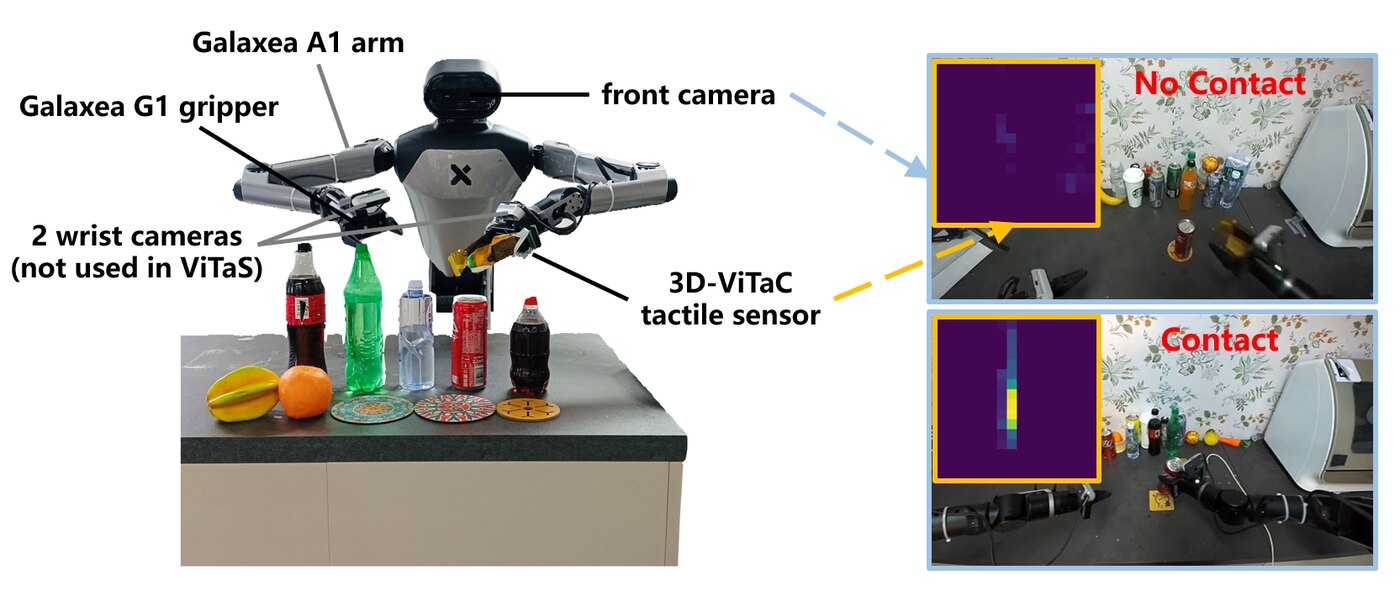
- Uses FlexiTac as all or part of its tactile sensor.
- Inspired by FlexiTac
- Draws on FlexiTac as a design reference or early prototype. Confirmed with the authors.


Bringing Human Touch to Robots: The Future of Tactile Sensing
Industrial-grade multimodal tactile sensors — 5× the resolution of a human fingertip, integrating pressure, vibration, and temperature.

Tactile Sensors: The Touch that will Transform Robotics
Multimodal fingertip sensing (pressure, temperature, audio, accelerometer) fused with AI for real-time slip prevention and dexterous humanoid manipulation.
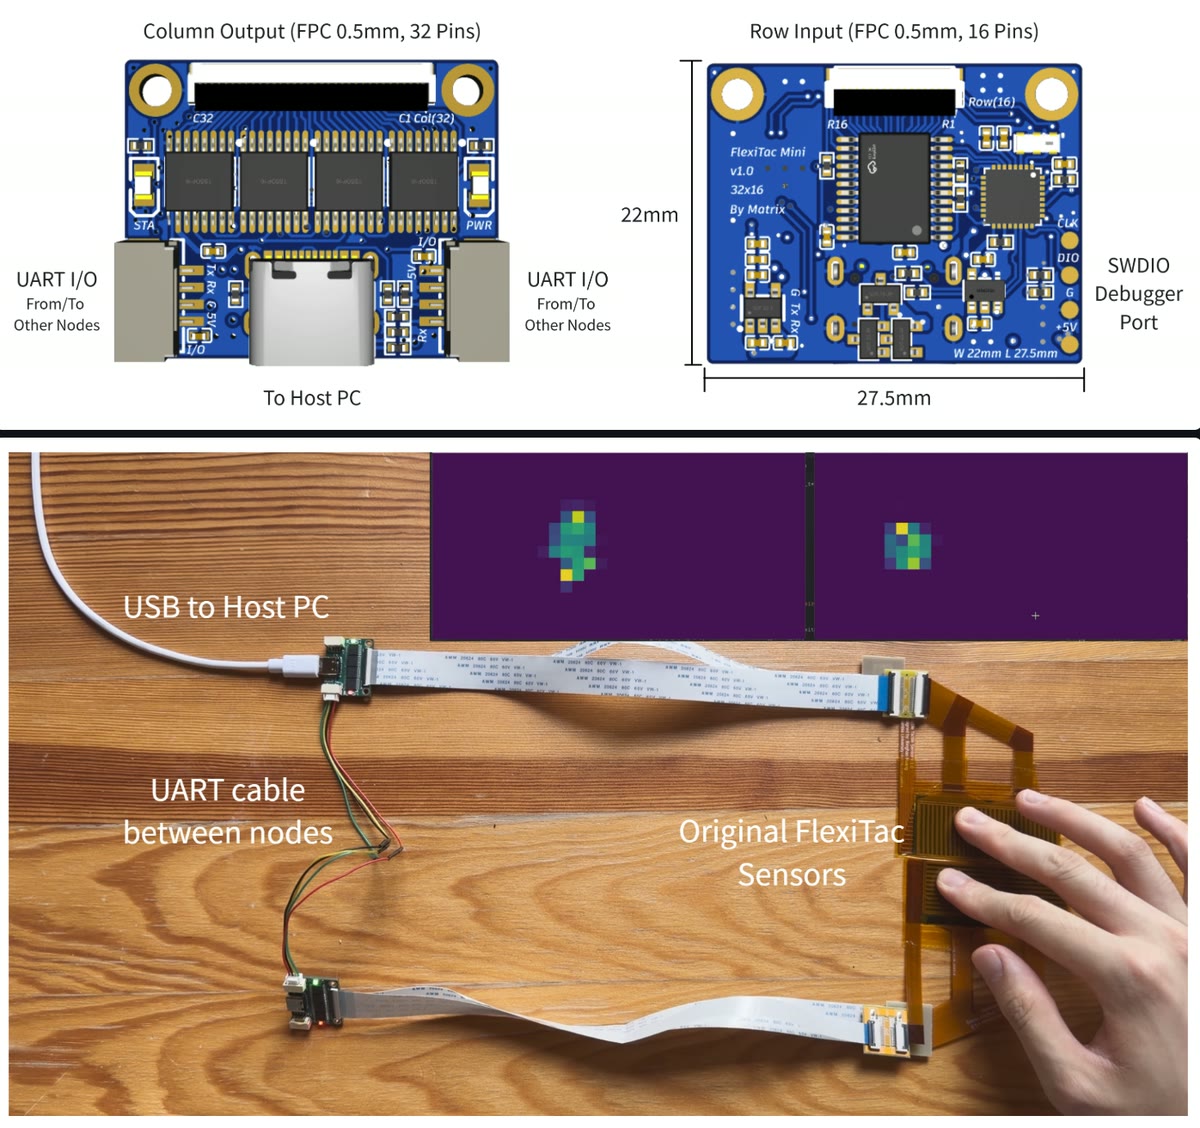
FlexiTac Mini: A Compact, Daisy-Chainable Readout Board for FlexiTac
A 27.5 × 22 mm board with a 150 MHz Cortex-M4 and 12-bit ADC (60+ FPS). Two 1 Mbps UART ports daisy-chain sensors: each node forwards its neighbours' frames, so the host reads the whole chain from any node's USB port.
Multi-Modal Manipulation via Multi-Modal Policy Consensus
Best Paper Award — CVPR 2026 Workshop on Multi-Sensory Modeling for Embodied Intelligence
Media: Featured in Video Friday — IEEE Spectrum


Deform360: A Massive Multi-view Visuotactile Dataset for Deformable World Models
198 objects, 23.3M total frames, and 215.7 h of high-quality visuo-tactile data captured with FlexiTac sensors.


No works in this category yet.
Contact
Please email binghao.huang@columbia.edu for any questions.
Have a relevant work? Open a PR or issue to add it.
Maintained by FlexiTac Team